
slam
3
minutes
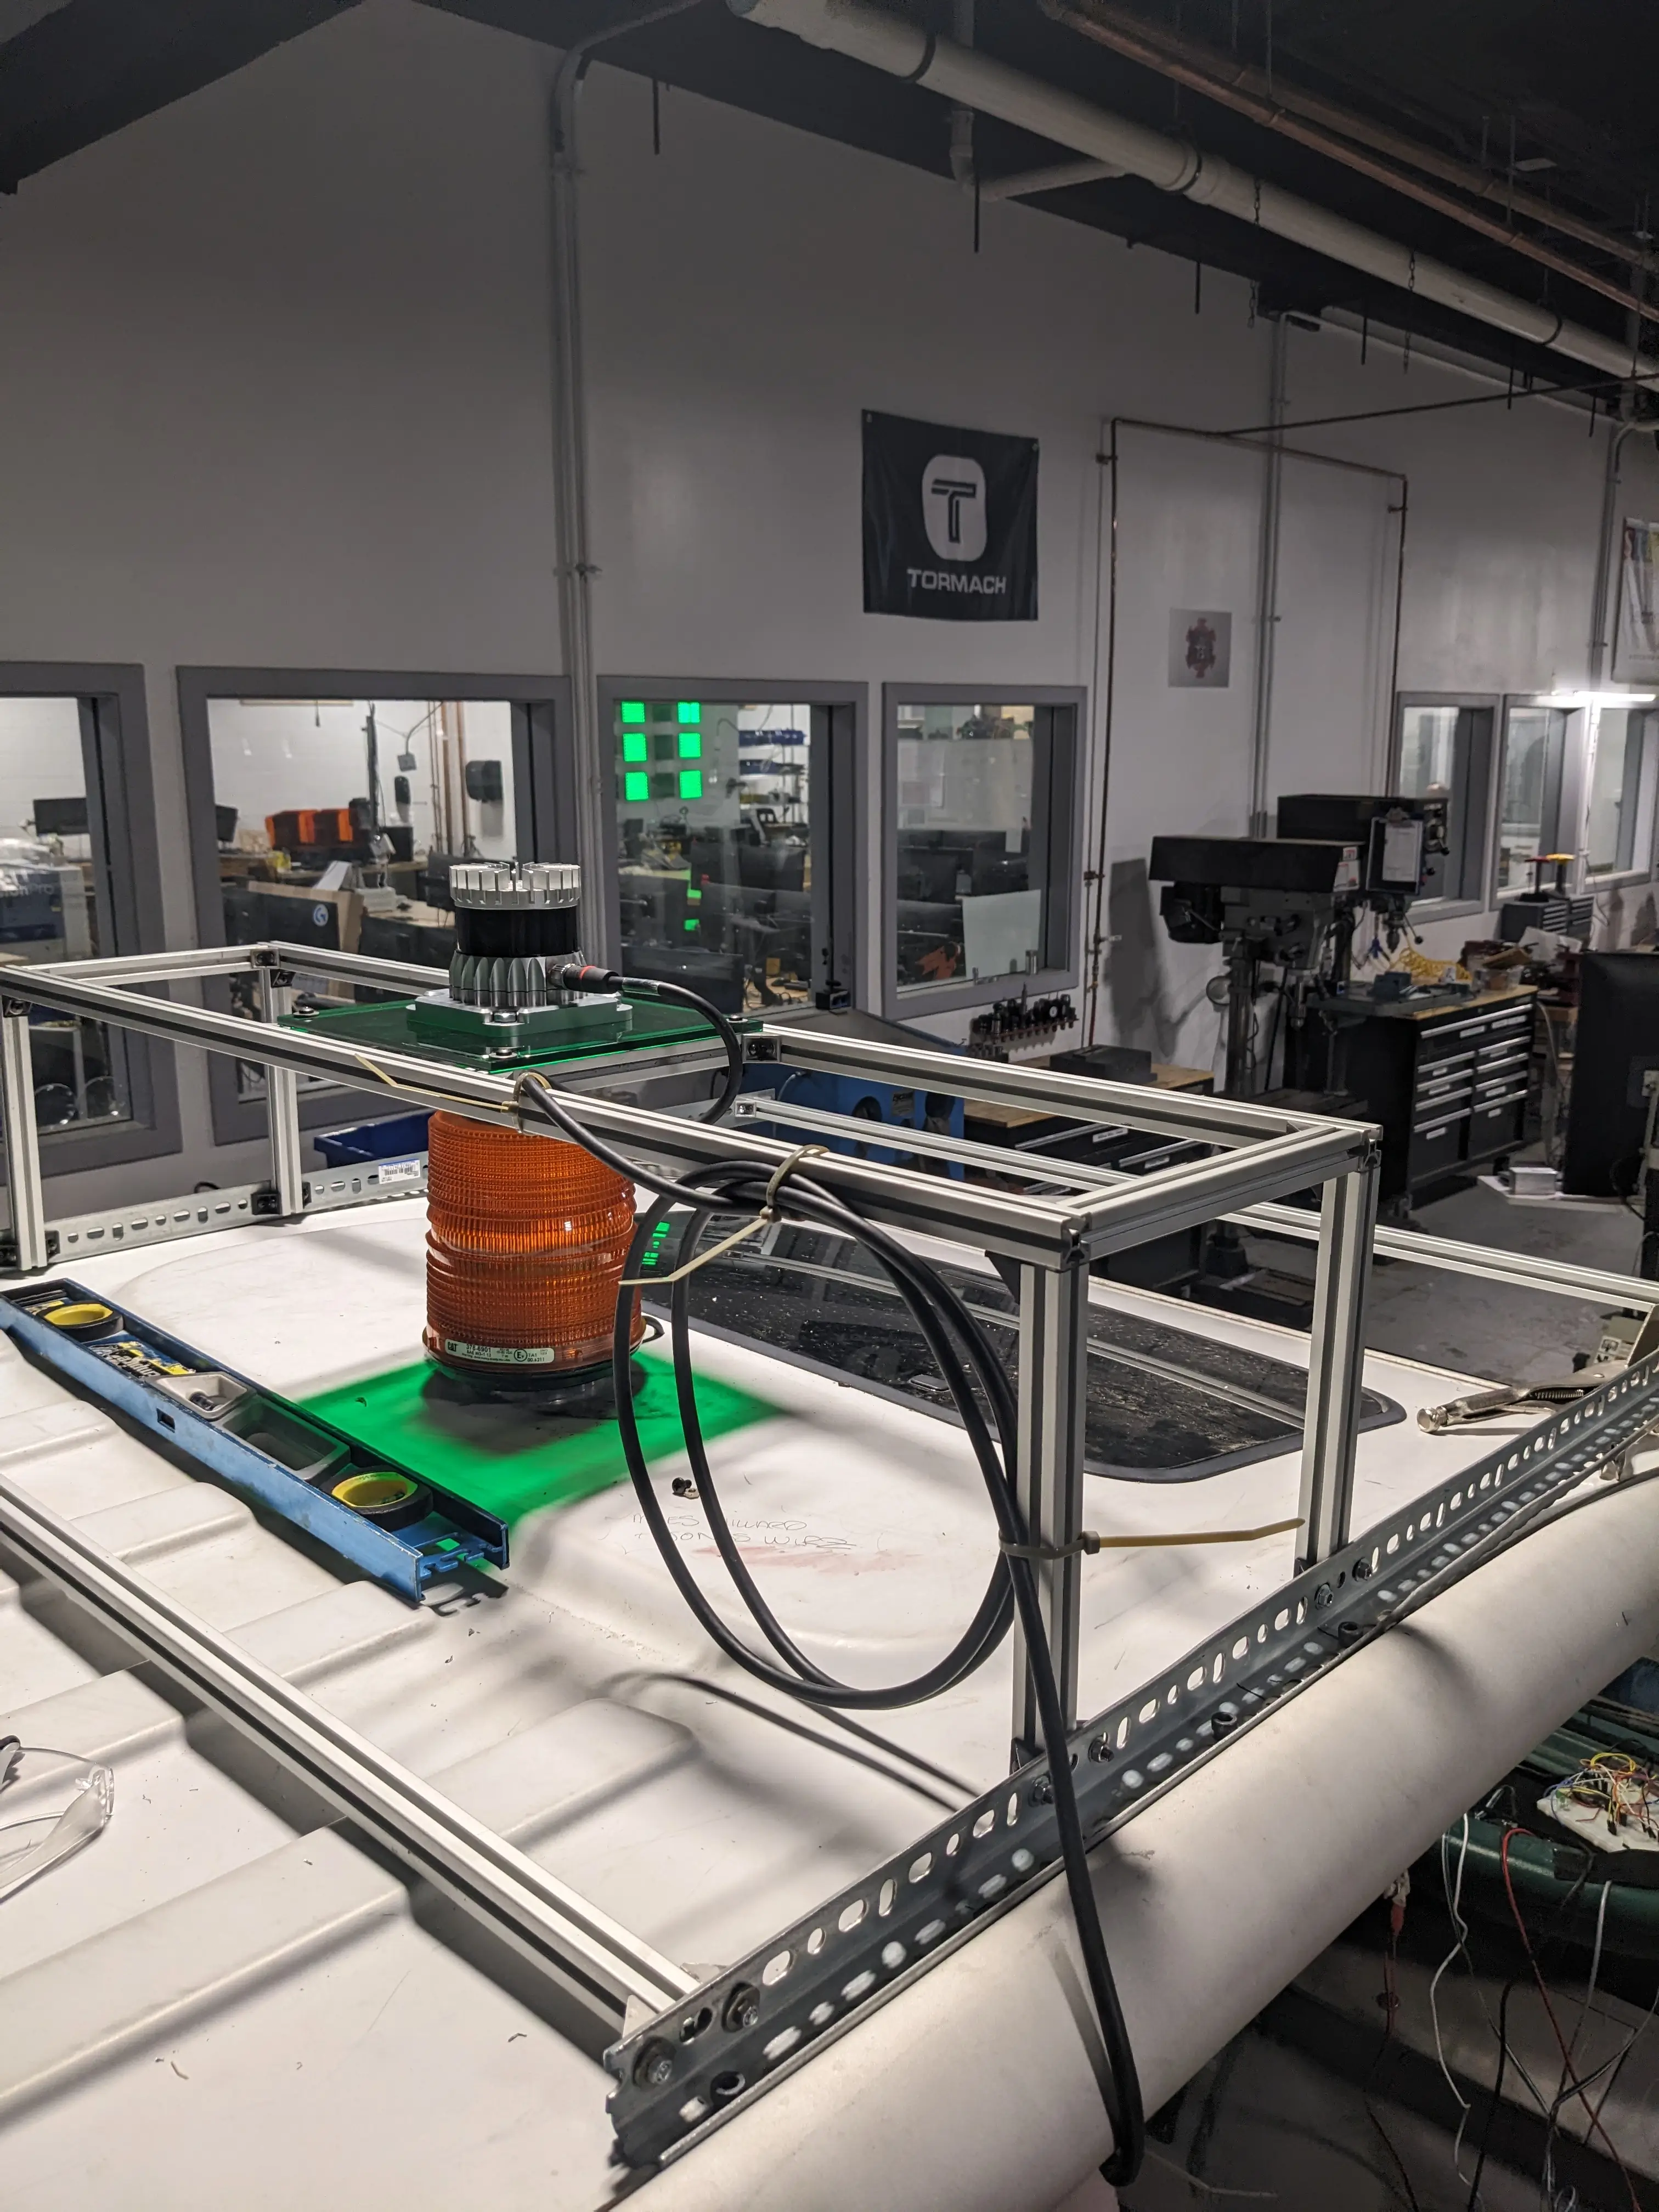
This week was about giving the LiDAR a proper residence on the golf cart. Up until now it has been taped to the roof, which was fine for a quick demo but not exactly the kind of rigid mounting that SLAM wants (or I was comfortable with). If the sensor shifts even a little between runs, the map and the live scan stop lining up, which means I would have to remap the whole school… Jonas and I finally decided it was time to build a real roof rack out of 8020 aluminum extrusion and some random angled steel we had lying around.
3
minutes
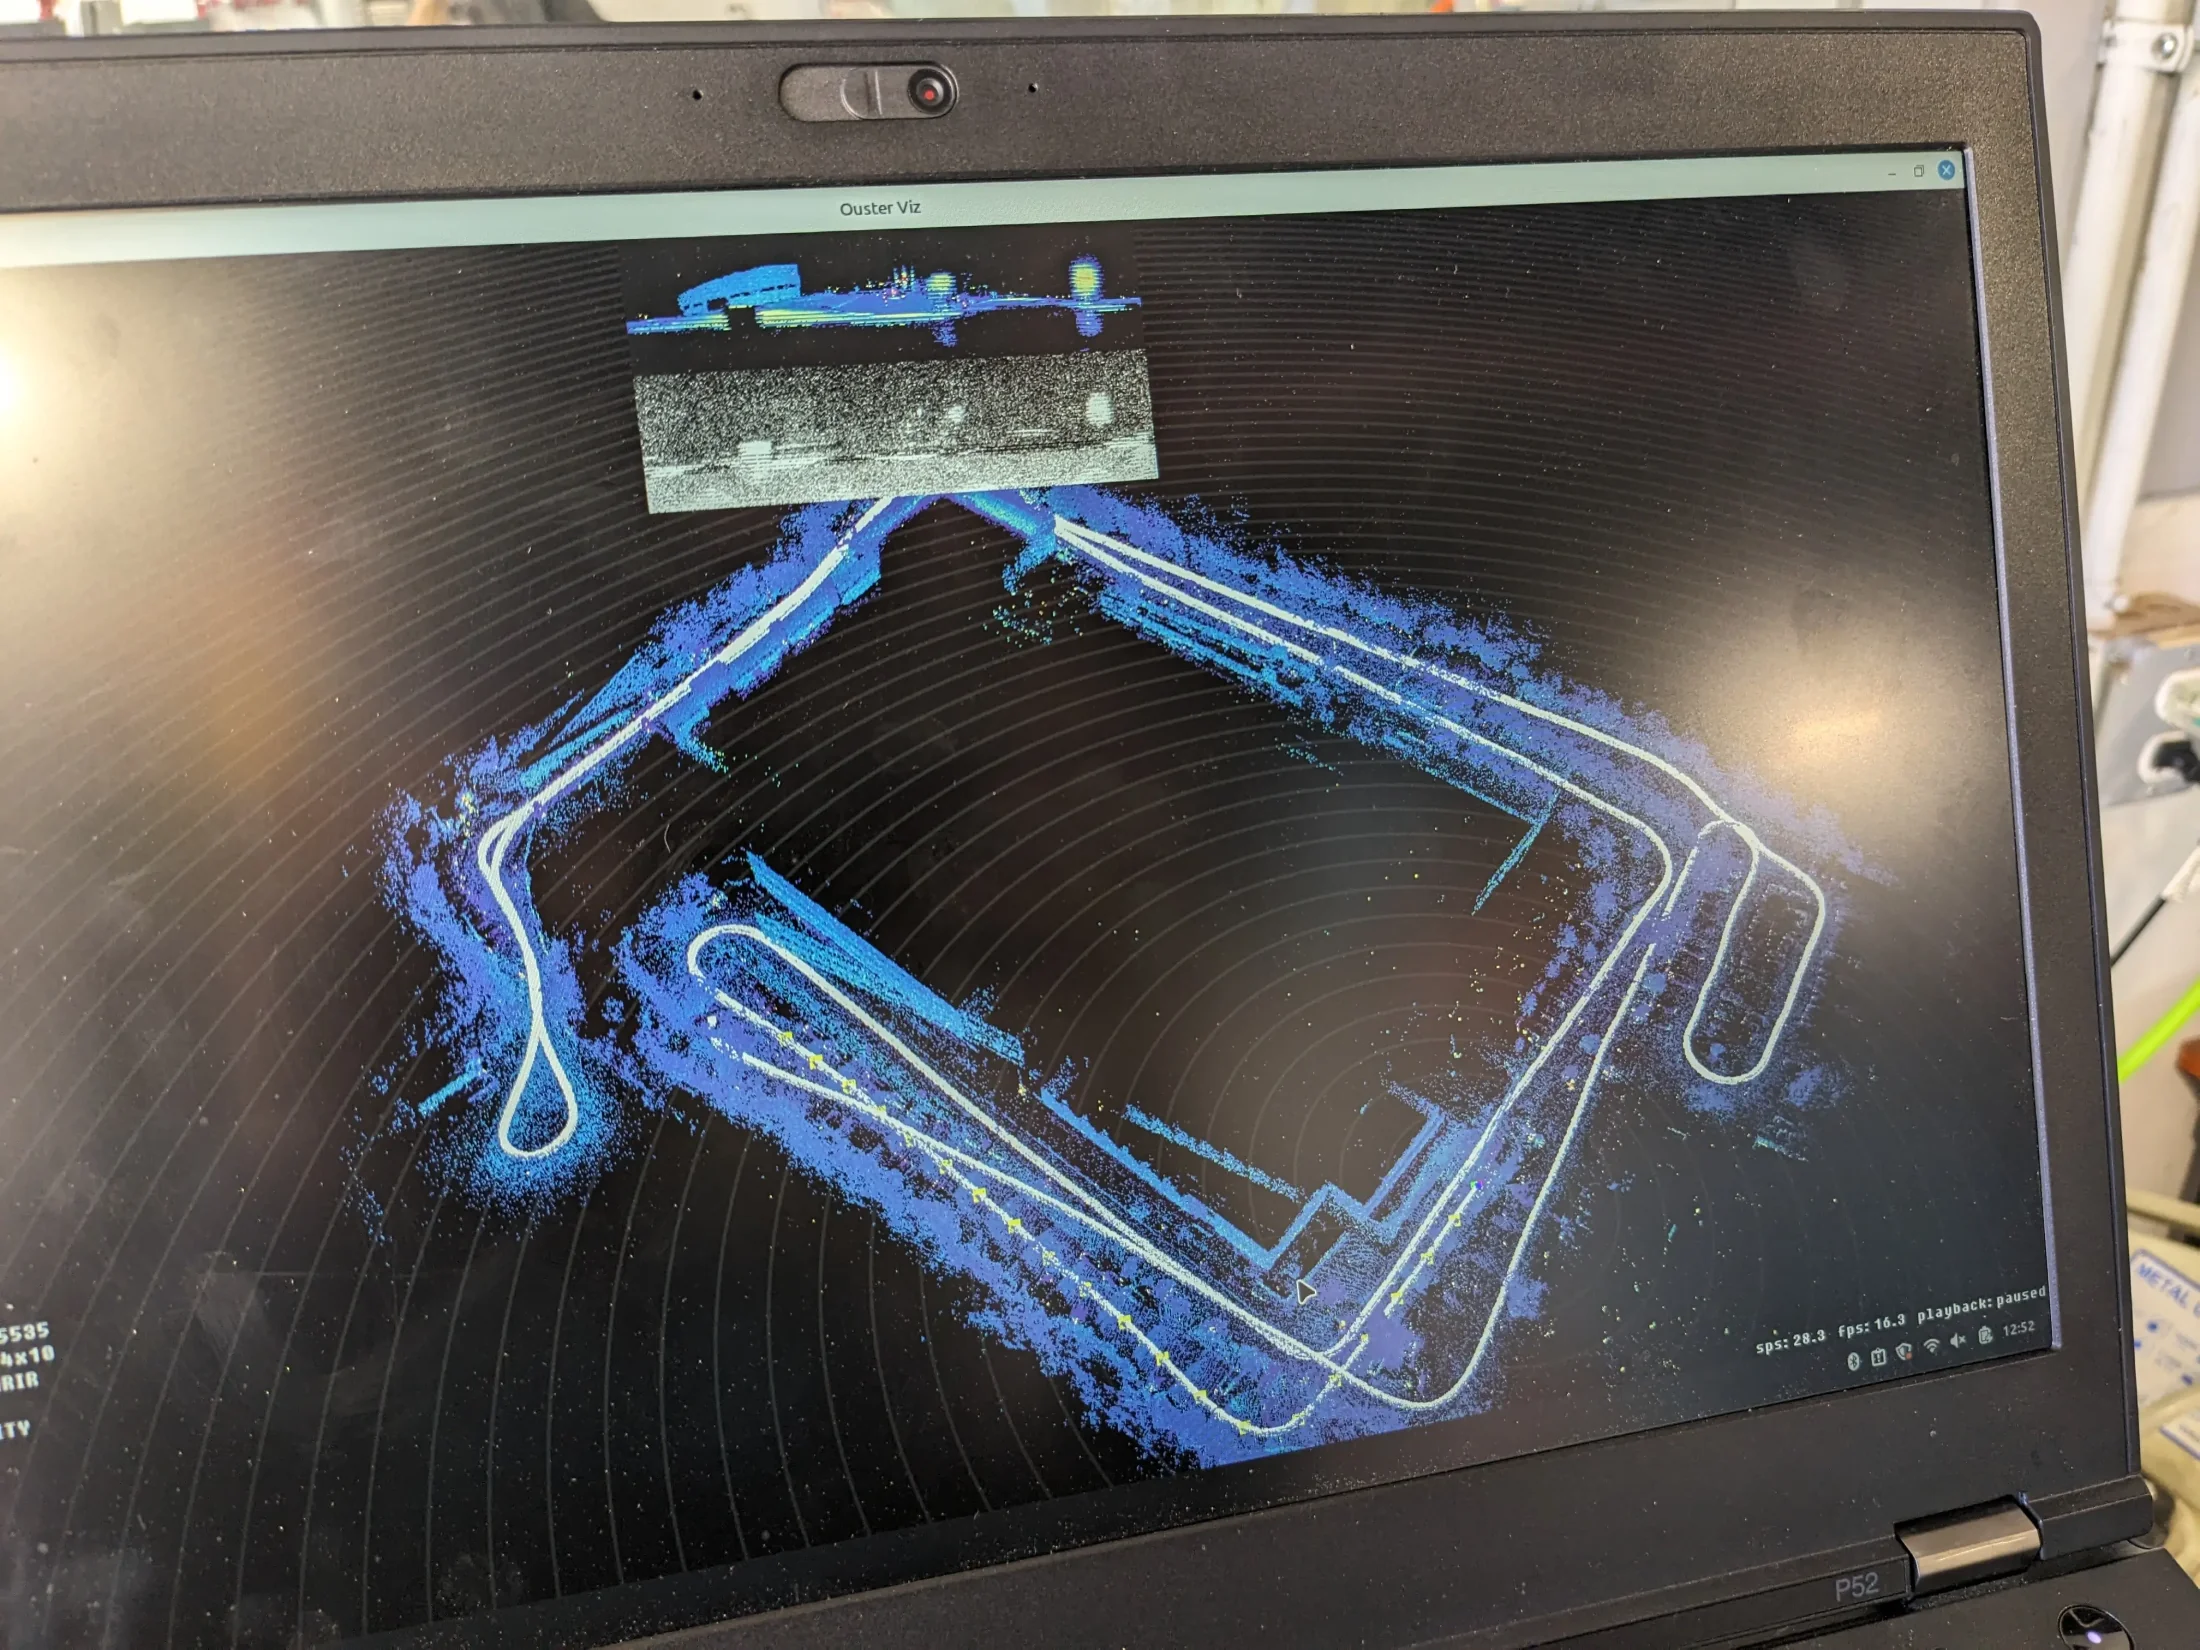
This week was almost entirely golf cart. I started out by installing the Python SDK for the Ouster LiDARs, and once I got all the libraries compiled, visualizing the sensor data was actually pretty easy. From there I moved on to the much bigger task: processing the 40 GB .pcap file that Jonas and I recorded with Ouster Studio the week before while driving around campus for about 30 minutes.
2
minutes
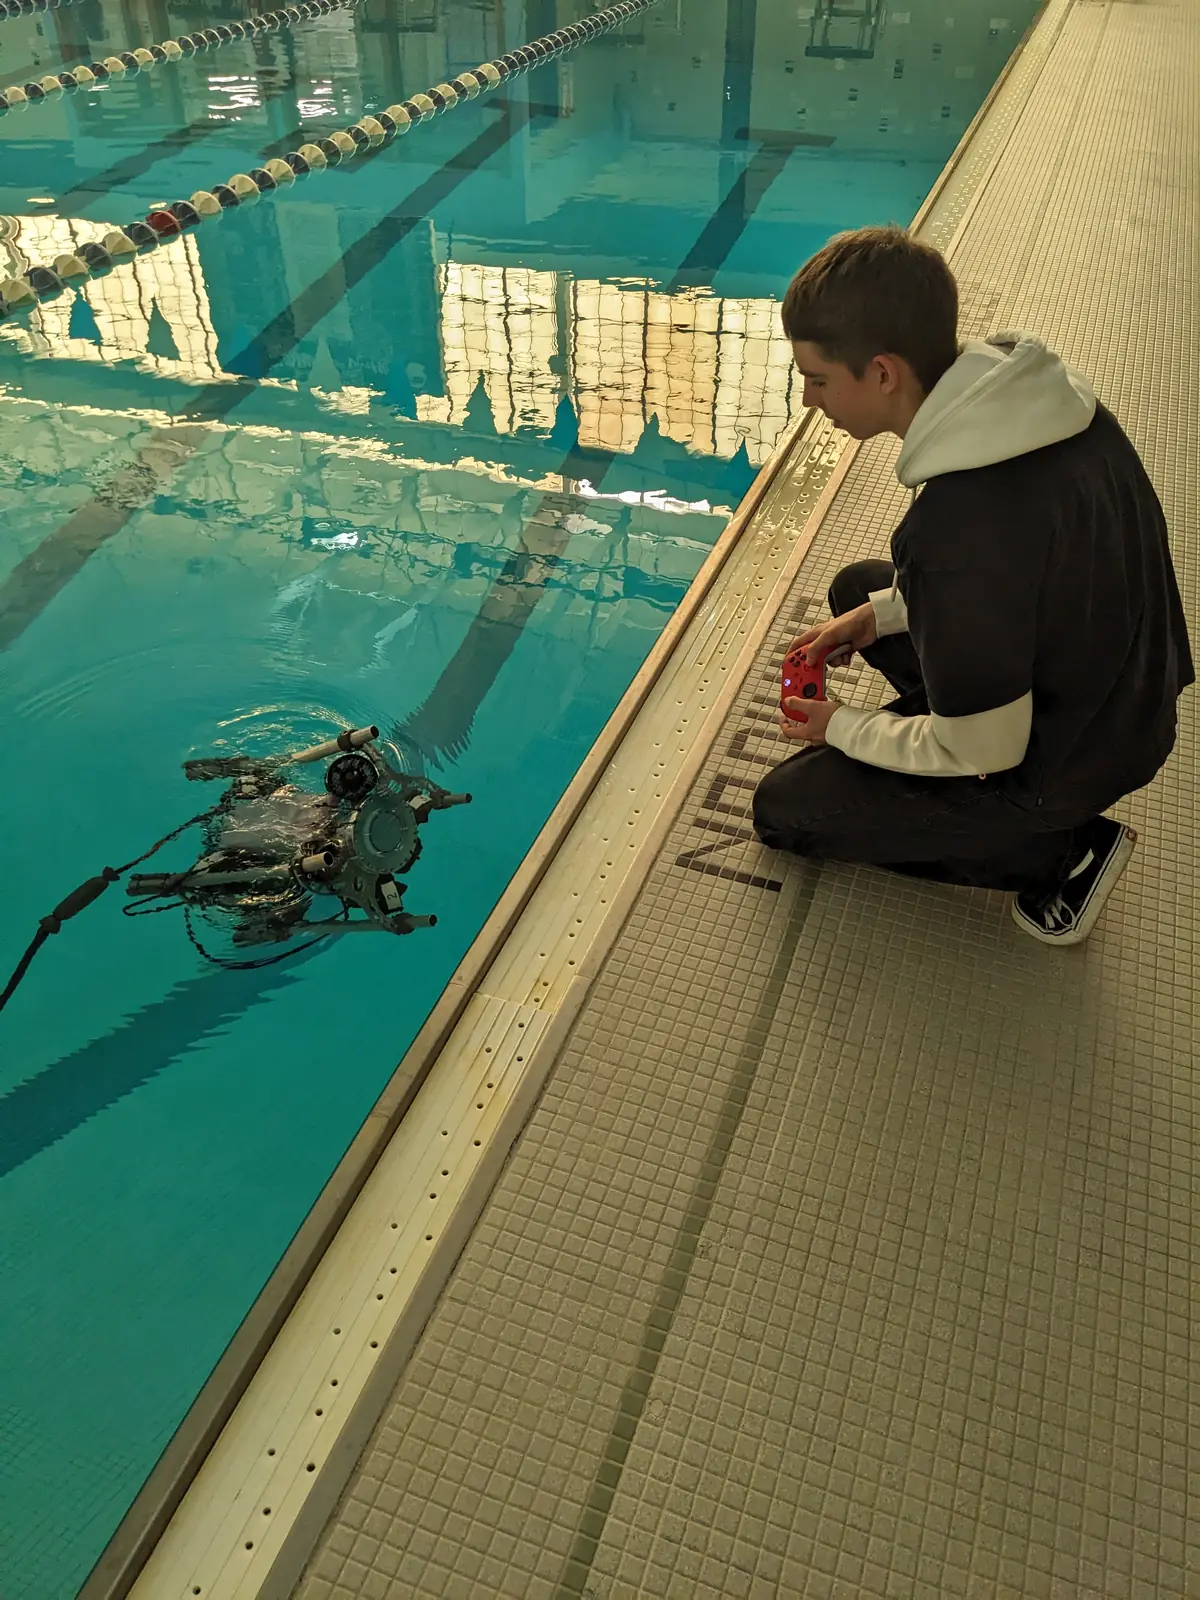
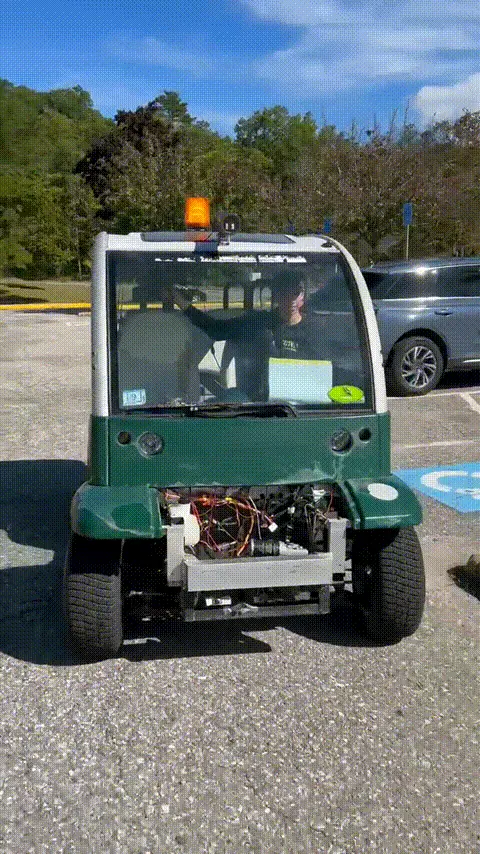
This week I split my time between the ROV and the golf cart, and both of them finally decided to cooperate… mostly.
On the ROV side, one of the ESCs decided to let the magic smoke out. I soldered in a new one (no picture sadly) and that brought the motor back to life. On Thursday, Tim helped me get all the motors spinning in the correct directions, which was a big win.
3
minutes
This week was our first full week of school, and I wanted to take advantage of that, however I was out sick on Thursday which didn’t help.
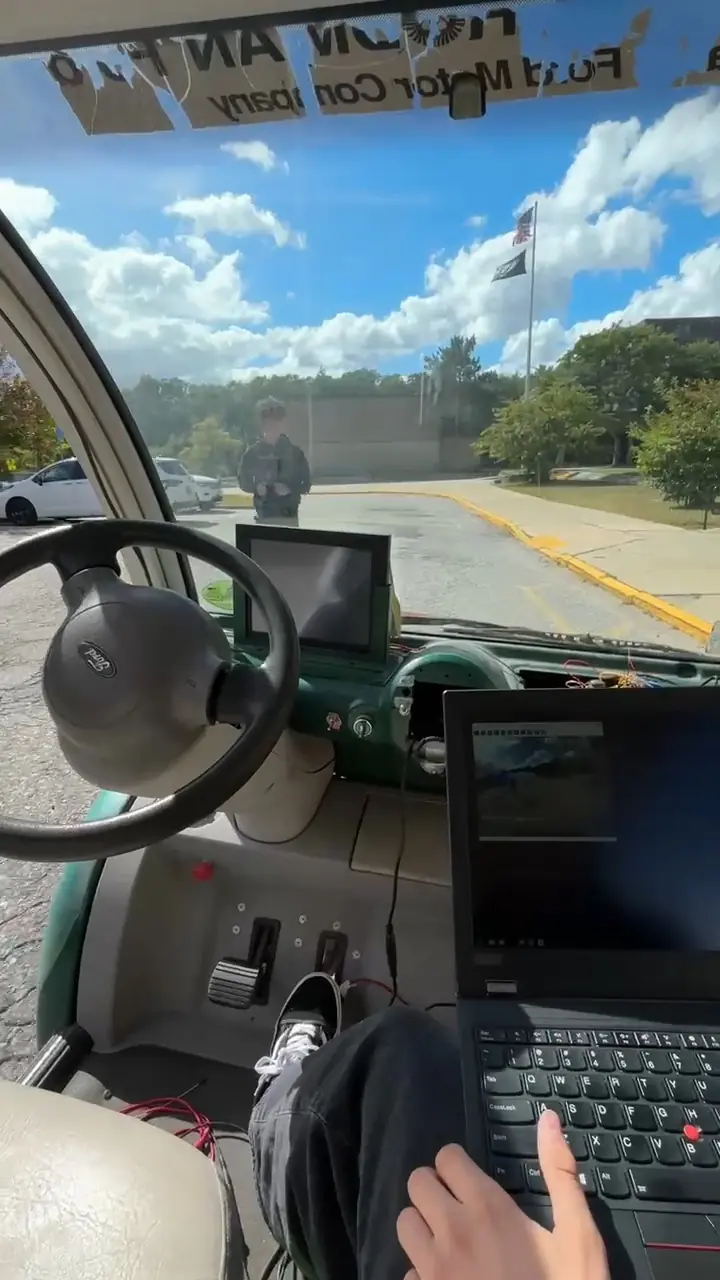
Nonetheless, I made a big discovery as to why I was having such a difficult time controlling the golf cart’s throttle via serial. I talked to Roman Rice, the creator of the driver board, and we determined that the issue I was experiencing was not a software issue.
3
minutes
This week in shop, I was very productive.
I spent time working on both the ROV and the golf cart, which both had a lot done to them, especially on Thursday which is our new afterschool club day.
In terms of the golf cart, the control system has been revamped… Instead of using a Metro Mini microcontroller, we are using an ESP32 which is capable of better hardware control. This means we can more accurately read the rotary encoder (with dedicated interrupt pins) and the PPM signal for the radio receiver simultaneously without interference.